E4Torsional and flexural-torsional buckling of single angles and members without slender elements
PDF page 109 · AISC 360-22
This section applies to singly symmetric and unsymmetric members, certain doubly symmetric members, such as cruciform or built-up members, and doubly symmetric members when the torsional unbraced length exceeds the lateral unbraced length, all without slender elements. These provisions also apply to single angles with b/t>0.71E/Fy, where b is the width of the longest leg and t is the thickness.
The nominal compressive strength, Pn, shall be determined based on the limit states of torsional and flexural-torsional buckling:
Pn=FnAg
(E4-1)
The nominal stress, Fn, shall be determined according to Equation E3-2 or E3-3, using the torsional or flexural-torsional elastic buckling stress, Fe, determined as follows:
(a) For doubly symmetric members twisting about the shear center
Fe=(Lcz2π2ECw+GJ)Ix+Iy1
(E4-2)
(b) For singly symmetric members twisting about the shear center where y is the axis of symmetry
Fe=(2HFey+Fez)[1−1−(Fey+Fez)24FeyFezH]
(E4-3)
User Note: For singly symmetric members with the x-axis as the axis of symmetry, such as channels, Equation E4-3 is applicable with Fey replaced by Fex.
(c) For unsymmetric members twisting about the shear center, Fe is the lowest root of the cubic equation
CwFex= warping constant, in. 6(mm6)=(rxLcx)2π2E
(E4-5)
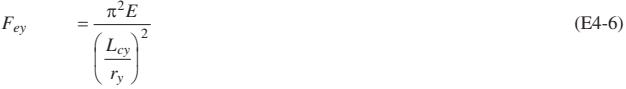
Figure description:
Equation (E4-6:Fey=(ryLcy)2π2E
Key Entities:
Fey: Elastic buckling stress about the y-axis.
E: Modulus of elasticity of steel.
Lcy: Effective length of the member for buckling about the y-axis.
ry: Radius of gyration about the y-axis.
FezGH=(Lcz2π2ECw+GJ)Agrˉo21= shear modulus of elasticity of steel =11,200ksi(77,200MPa)= flexural constant =1−r2xo2+yo2
(E4-7)
(E4-8)
Ix,IyJKxKyKz= moment of inertia about the principal axes, in. 4(mm4)= torsional constant, in. 4(mm4)= effective length factor for flexural buckling about x-axis = effective length factor for flexural buckling about y-axis = effective length factor for torsional buckling about the longitudinal axis
Lcx= effective length of member for buckling about x-axis, in. (mm) =KxLx
Lcy= effective length of member for buckling about y-axis, in. (mm) =KyLy
Lcz= effective length of member for buckling about longitudinal axis, in. (mm) =KzLz
Lx,Ly,Lzrˉorˉo2rxryxo,yo= laterally unbraced length of the member for each axis, in. (mm) = polar radius of gyration about the shear center, in. (mm) =xo2+yo2+AgIx+Iy= radius of gyration about x-axis, in. (mm) = radius of gyration about y-axis, in. (mm) = coordinates of the shear center with respect to the centroid, in. (mm)
User Note: For doubly symmetric I-shaped sections, Cw may be taken as I h y o2 4, where ho is the distance between flange centroids, in lieu of a more precise analysis. For tees and double angles, the term with Cw may be omitted when computing Fez.
(d) For doubly symmetric I-shaped members with minor-axis lateral bracing offset from the shear center
Fe=[Lcz2π2EIy(4ho2+ya2)+GJ]Agro21
(E4-10)
where
horo2xaya= distance between flange centroids, in. (mm) =rx2+ry2+ya2+xa2= bracing offset distance along x-axis =0= bracing offset distance along y-axis, in. (mm)
(e) For doubly symmetric I-shaped members with major-axis lateral bracing offset from the shear center
ro2xaya=rx2+ry2+ya2+xa2= bracing offset distance along x-axis, in. (mm) = bracing offset distance along y-axis =0
(f) For all other members with lateral bracing offset from the shear center, the elastic buckling stress, Fe, shall be determined by analysis.
User Note: Bracing offset from the shear center is often referred to as constrained-axis torsional buckling and is discussed further in the Commentary. Members that buckle in this mode will exhibit twisting because the braces restrain only lateral movement.